Mohammed Almsitef
Robotics & AI Engineer
I build systems that perceive, reason, and act from deep learning models for vision and language to the real-time autonomy stacks that run them on physical robots.
About
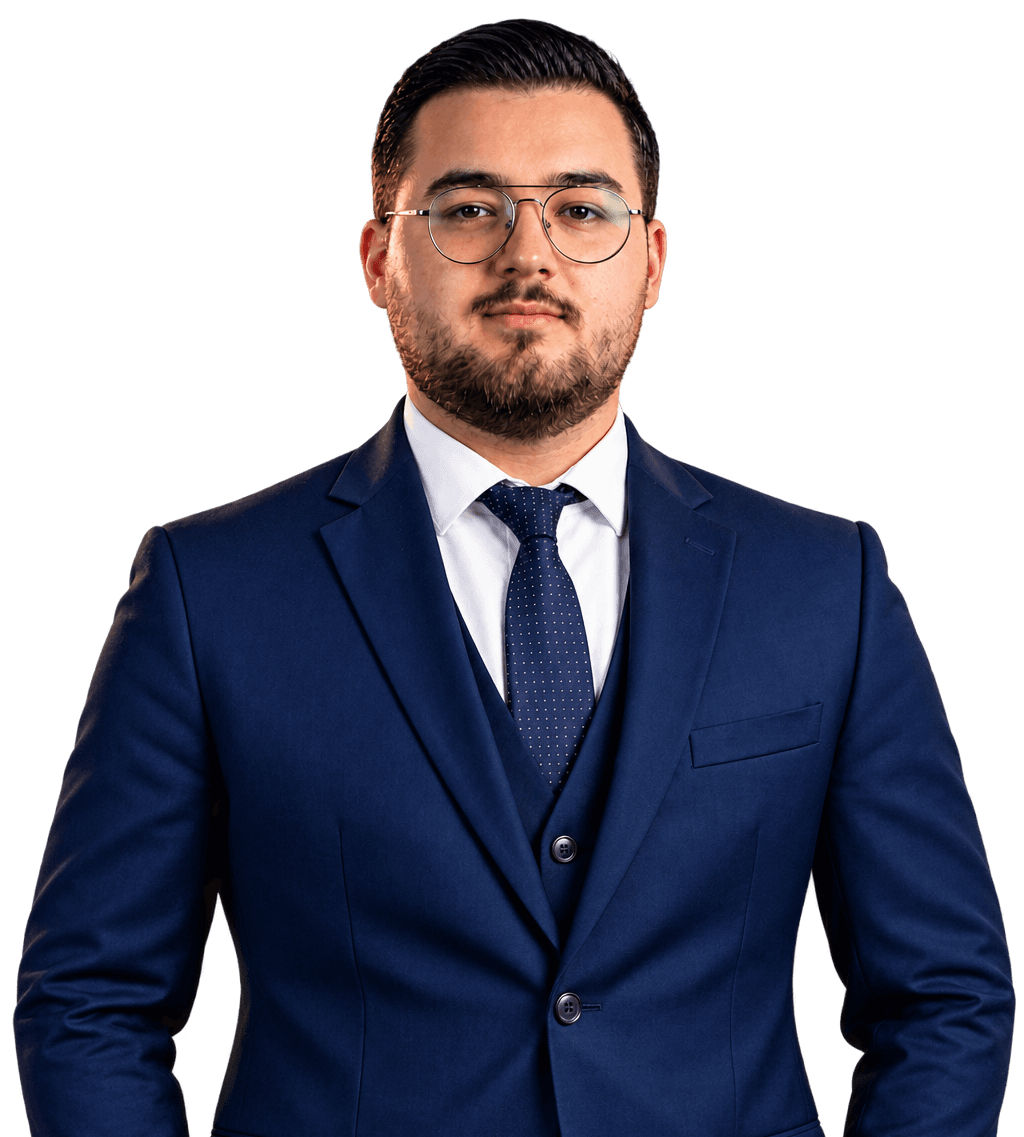
I'm a robotics and AI engineer who graduated from the University of Aleppo's Faculty of Informatics Engineering in 2025, specializing in Artificial Intelligence, with Honors (GPA 85.317/100).
Since June 2025 I've worked as a Robotics Engineer at SWB, where I build ROS 2 software for deployed robots and the applied-AI capabilities that run on them — object recognition and natural spoken interaction with people. Robotics is the part of the stack I taught myself after graduating, on top of the deep learning and NLP foundation from my degree.
My favourite problems sit at that intersection: training a model is one thing, getting it to run reliably on hardware with real constraints — weak actuators, a single sensor doing the job of several, a network link that isn't always there — is another. That's the kind of work behind my graduation project, a Coursera course-recommendation engine trained end to end on data I scraped myself, and my first ROS 2 project, two Lego EV3 robots mapping a space together over an MQTT bridge.
Projects
Manara Robot
2025 — PresentThe ROS 2 platform behind a service robot deployed to help pilgrims at the Two Holy Mosques in Mecca and Medina — autonomous navigation, self-docking and charging, and the sensor pipeline that a 25-language on-screen AI assistant rides on top of.
- ROS 2
- Nav2
- SLAM Toolbox
- C++
- Modbus / RS-485
- Point Cloud (PCL)
- REST / WebSocket
- systemd
Two Lego Mindstorms EV3 robots build a single shared map together, bridged into ROS 2 and SLAM Toolbox over MQTT — my first ROS 2 project, built with hardware that was never meant to run it.
- ROS 2
- Python
- MQTT / Mosquitto
- SLAM Toolbox
- TF2
- Lego Mindstorms EV3 (ev3dev2)
- Gazebo
A university graduation project that recommends the right Coursera course from a free-text description of what a learner already knows, trained end to end on a dataset I scraped and cleaned myself.
- Python
- TensorFlow / Keras
- Gensim (Word2Vec)
- NLTK
- BeautifulSoup
- MySQL
- SQLAlchemy
- Django
- Keras-Tuner
Skills
Languages
- Python
- C++17 / 20
- CUDA
- SQL
- Bash
- CMake
Machine Learning
- scikit-learn
- XGBoost / LightGBM
- Feature engineering
- Hyperparameter search (Optuna)
- Model evaluation & calibration
- Time-series forecasting
Deep Learning
- PyTorch
- TensorFlow / Keras
- CNNs & Vision Transformers
- Reinforcement learning (PPO / SAC)
- Distributed & mixed-precision training
- Model compression
Computer Vision
- OpenCV
- Detection (YOLO / DETR)
- Semantic & instance segmentation
- Stereo & depth estimation
- Visual SLAM / VIO
- Camera calibration
NLP & LLMs
- Hugging Face Transformers
- Fine-tuning (LoRA / QLoRA)
- RAG & vector search
- Embeddings & semantic search
- Tokenization, spaCy / NLTK
- Evaluation & guardrails
Robotics
- ROS 2 (Humble / Jazzy)
- Nav2 & MoveIt 2
- Sensor fusion (EKF / UKF)
- Motion planning
- Real-time control (MPC / PID)
- Behavior trees
Simulation
- NVIDIA Isaac Sim
- Gazebo / Ignition
- MuJoCo
- Domain randomization
- Sim-to-real transfer
- Foxglove / rviz2
MLOps & Deployment
- Docker & CI/CD
- Weights & Biases, MLflow
- ONNX / TensorRT
- Jetson & edge inference
- Data & experiment versioning
- Monitoring & drift detection
Embedded & Hardware
- Linux PREEMPT_RT
- STM32 / FreeRTOS
- CAN / CANopen
- LiDAR, IMU, depth cameras
- Time synchronization
- Hardware-in-the-loop
Experience
Robotics Engineer · SWB
June 2025 — PresentROS 2 and applied AI for robots — object detection and natural spoken interaction with people.
- Own the ROS 2 platform behind Manara, an in-production service robot deployed at the Two Holy Mosques — autonomous navigation, motor control, and a self-docking/charging system rewritten from scratch.
- Develop and maintain ROS 2 software running on deployed robots.
- Build and integrate applied-AI capabilities on the robots, including object recognition and voice-based interaction with people.
- Joined the team before graduating and have stayed on full-time since.
Education
- B.Sc. in Informatics Engineering · Artificial Intelligence · University of Aleppo, Faculty of Informatics Engineering · graduated with Honors, GPA 85.317/1002021 — 2025
Contact
Let’s work together.
I'm open to full-time roles, contract work, and interesting collaborations — especially anything involving autonomy in the real world. Email is the fastest way to reach me.
Email me
- Based in
- Aleppo, Syria
- Response time
- Within a couple of days